
DC
Daniel Cranney
From Perception to Autonomy: Building Agentic Edge AI Robots with ROS 2
- Discuss this with your agent
- Open in Claude
- Open in ChatGPT
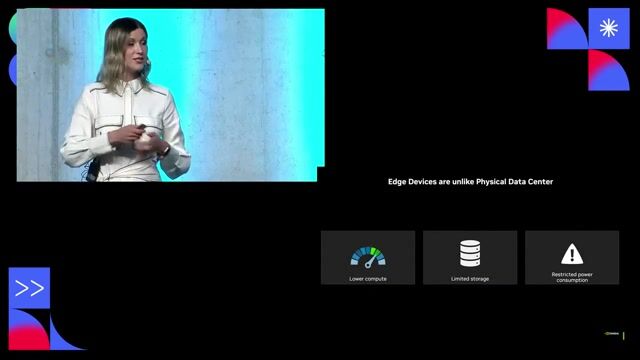
The next engineering moat is physical edge AI. Learn to build offline, agentic robots using ROS 2 and local LLMs. Master multi-model architectures for real-world autonomy.
Matching moments
3:55 min
Technical catalysts driving real-world artificial intelligence
 Clemens Wasner +3 · World Congress 2026 Europe
1:20 min
Shifting focus from large language models to physical AI
 Sergio Perez · World Congress 2026 Europe
1:44 min
Navigating hardware constraints and edge computing challenges
 Thomas Tomow · World Congress 2025
3:21 min
Reducing cloud dependency with on-device edge AI models
 Precious Osaro · World Congress 2026 Europe
1:36 min
Future predictions for autonomous agent environments and robotics
 Philipp Schmid · World Congress 2025
1:50 min
Overview of the Edge AI ecosystem and tech stack
 Maxim Salnikov · World Congress 2025
More from World Congress 2026 Europe
Related videos
Related articles

BB
Benedikt Bischof

BR
Benjamin Ruschin

MH
Michael Hunger
N
Neo4j

From learning to earning
Jobs that call for the skills explored in this talk.
20 days ago
Principal Software Engineer, AI Inference Runtime

ARM
Seattle, WA, United States
Expert
$262k
Compilers
Low Latency
Concurrency
20 days ago
Principal Software Engineer, AI Inference Cloud
ARM
Seattle, WA, United States
Expert
$262k
Pytorch
TensorRT
Kubernetes
21 days ago
Senior AI Developer
PwC
United States
Expert
Remote
Docker
Github
Fastapi
20 days ago
Principal Software Engineer, AI Compute Infrastructure
ARM
Seattle, WA, United States
Expert
$262k
Linux
Grafana
Pytorch
about 1 month ago
•
Verified
ML Engineer
Docker, Inc.
Seattle, United States
Expert
Remote
Go
20 days ago
Principal Software Engineer, AI Compute Platform
ARM
Seattle, WA, United States
Expert
$262k
Backend
Grafana
Pytorch