

World Congress 2026 Europe Jul 10, 2026 Session details

From Perception to Autonomy: Building Agentic Edge AI Robots with ROS 2

Moe Sani

The next engineering moat is physical edge AI. Learn to build offline, agentic robots using ROS 2 and local LLMs. Master multi-model architectures for real-world autonomy.

Pause
Mute Enter Fullscreen
#1 about 3 min

Introduction to physical AI and the physical world

How moving beyond traditional cloud AI to physical environments introduces new dynamics and applications like robotics.

#2 about 2 min

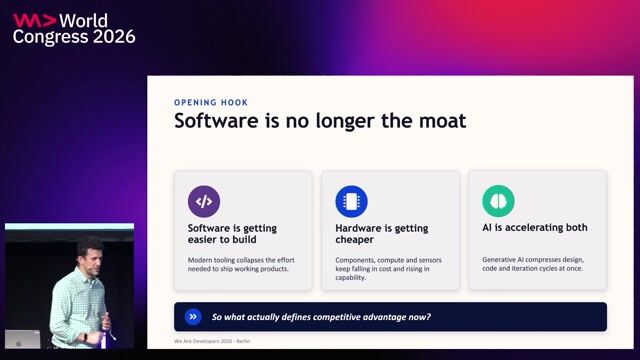
Cheaper software generation and the shifting technology moat

How token-based code generation makes traditional software features cheaper and drives the need for a new competitive advantage.

#3 about 2 min

Tracing technology waves to uncover future engineering value

Why value moves up the stack as past technologies commoditize and how engineers can diversify their skills.

#4 about 3 min

High value in integrated systems and real world complexity

Why the unpredictability and noise of physical sensors make real-world deployment the next defensible engineering frontier.

#5 about 3 min

Key drivers and definitions for physical edge artificial intelligence

The necessity of local inference for reliable real-time decision making without internet dependency in high-security environments.

#6 about 3 min

Cost and latency pressures pushing AI to the edge

How connected device explosion, new neural processing units, and high cloud transmission costs accelerate local AI adoption.

#7 about 2 min

Capturing physical world data through distributed hardware deployments

Why securing real-world hardware distribution networks replaces software features as the primary defensible business moat.

#8 about 2 min

Integrating agentic capabilities into ROS for physical intelligence

Patterns for connecting language models to robot operating systems to achieve physical world planning.

#9 about 3 min

Current limitations in agentic frameworks and edge hardware models

The unresolved challenges of expensive hardware fleets, lack of evaluation standards, and complex multi-modal data ingestion constraints.

#10 about 4 min

Deploying parallel models on custom hardware with Edge Impulse

An architecture walkthrough of an autonomous pipeline inspection robot using device models and simulation environments.

#11 about 4 min

Releasing Genie X and addressing unresolved robot recovery mechanics

The rollout of a new tool for edge models and a discussion regarding the ongoing challenge of mid-task robot recovery.

Matching moments

3:55 min

Technical catalysts driving real-world artificial intelligence

Clemens Wasner Clemens Wasner +3 · World Congress 2026 Europe

1:20 min

Shifting focus from large language models to physical AI

Sergio Perez Sergio Perez · World Congress 2026 Europe

1:44 min

Navigating hardware constraints and edge computing challenges

Thomas Tomow Thomas Tomow · World Congress 2025

3:21 min

Reducing cloud dependency with on-device edge AI models

Precious Osaro Precious Osaro · World Congress 2026 Europe

1:36 min

Future predictions for autonomous agent environments and robotics

Philipp Schmid Philipp Schmid · World Congress 2025

1:50 min

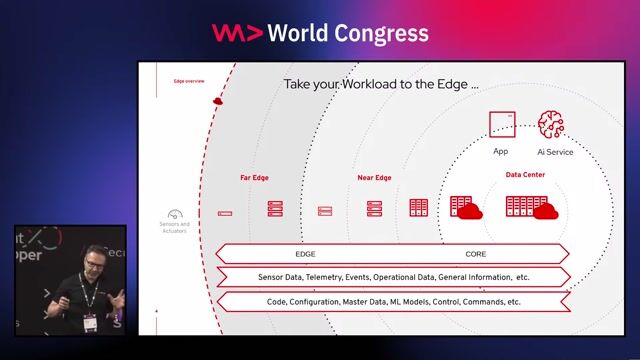
Overview of the Edge AI ecosystem and tech stack

Maxim Salnikov Maxim Salnikov · World Congress 2025

Upcoming sessions on this topic

Open session

World Congress 2026 North America

September 24, 2026 · 14:10–14:40

Stage 5

Edge AI: Running Agentic Intelligence Where Internet Can't Reach

Nitin Eusebius

AWS - Principal Solutions Architect
Nitin Eusebius
Open session

World Congress 2026 North America

September 24, 2026 · 11:00–11:30

Tech Leaders Stage

Building AI for the Physical World

Alex Spinelli, Eystein Stenberg, Gerardo Pardo-Castellote

Alex Spinelli
Eystein Stenberg
Gerardo Pardo-Castellote
Open session

World Congress 2026 North America

September 25, 2026 · 11:40–12:10

Stage 9

You Can’t Re-Run Sunlight: Designing ML Data Architectures for Physical AI

An Phan

Senior Data Infrastructure Engineer @ Hippo Harvest

An Phan
Open session

World Congress 2026 North America

September 24, 2026 · 16:10–16:40

Stage 5

From Software Agents to Physical Devices: Inside the Agentic Hardware Stack

Michael Yuan, Vivian Hu

Michael Yuan
Vivian Hu
Open session

World Congress 2026 North America

September 23, 2026 · 10:00–17:00

Stage 11

Building Stuff with GenAI - The Open Minded Workshop beyond OpenAI

Andreas Erben

CTO for Applied AI and Metaverse at daenet

Andreas Erben
Open session

World Congress 2026 North America

September 25, 2026 · 12:55–13:25

Stage 1

From Simulation to Reality: Overcoming the Data Scarcity Crisis in Physical AI

Mitesh Patel

NVIDIA Corporation, Developer Advocate -- Manager
Mitesh Patel